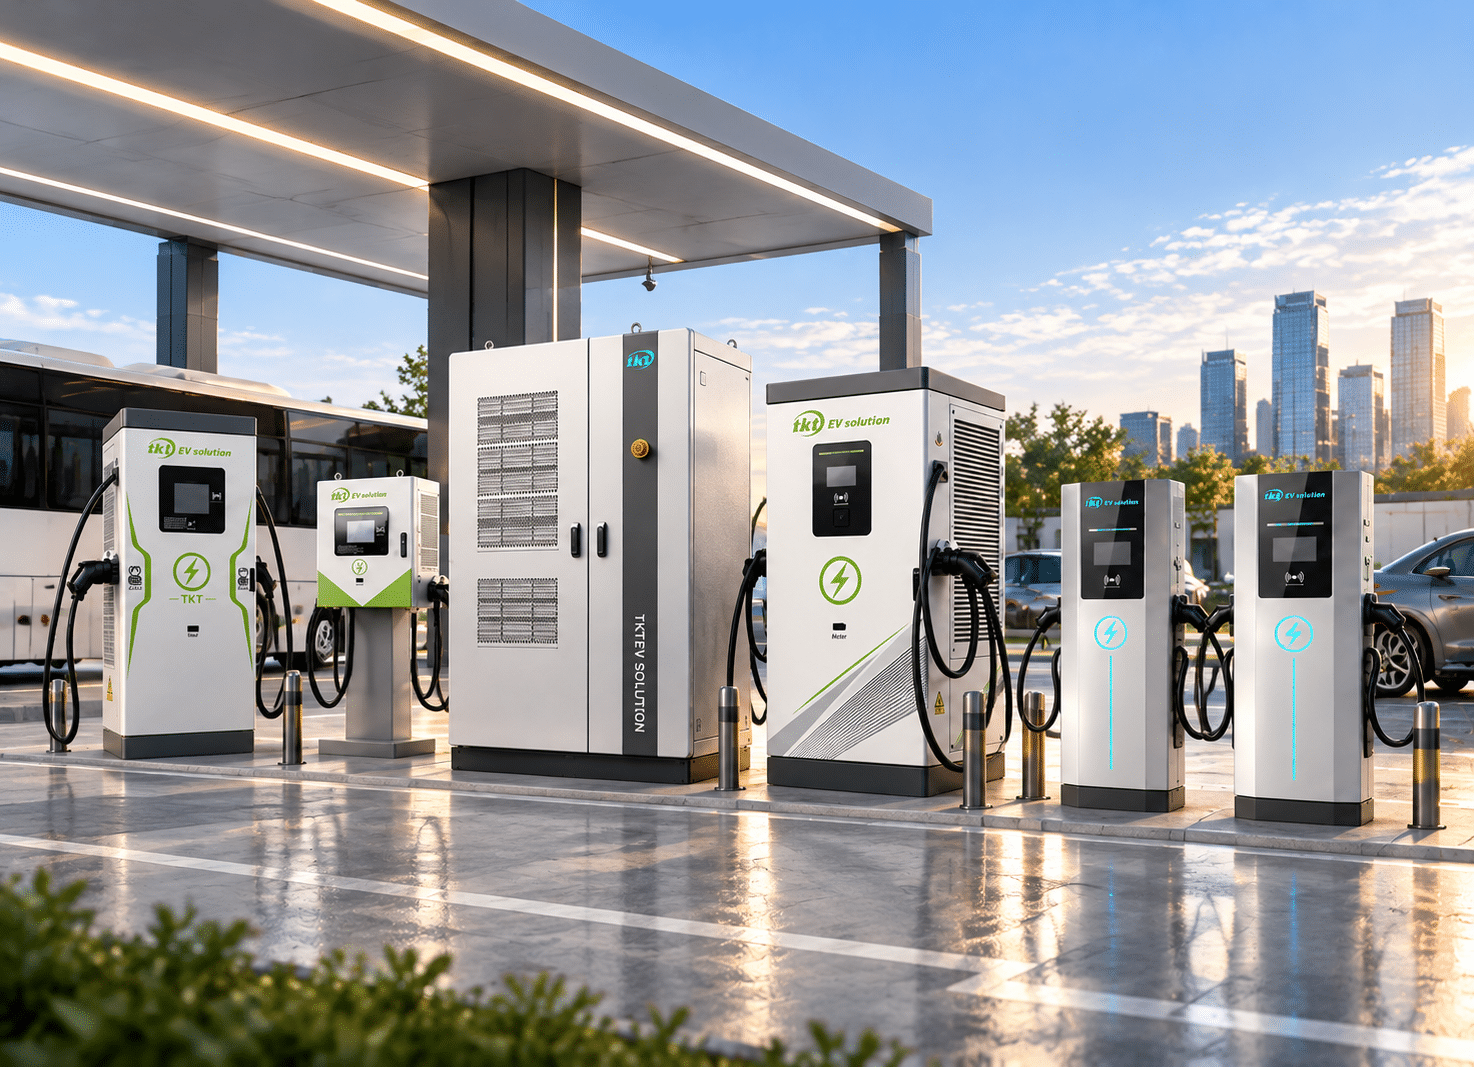
As the market share of new energy vehicles continues to rise, DC fast charging stations have become essential infrastructure in locations such as highway service areas, logistics parks, and commercial districts. While many purchasers are aware that dc ev charger offer faster charging speeds, they may not fully grasp the fundamental difference between DC fast charging and AC slow charging. AC charging stations rely on the vehicle’s onboard charger (OBC) to perform the AC-to-DC conversion; in contrast, DC charging stations handle this power conversion internally. They output adjustable, high-voltage direct current directly to the vehicle’s traction battery—bypassing the onboard charger—which enables high-power, fast charging at the scale of hundreds of kilowatts.
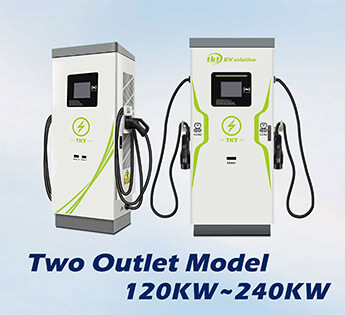
I. Overall Hardware Architecture of commercial electric vehicle charging station A standard integrated commercial electric vehicle charging station consists of five main components: the primary power circuit, the control and communication circuit, the auxiliary power supply, the cooling system, and the safety monitoring and metering unit. In contrast, a split-type DC charging system separates the power cabinet from the terminal charging unit, making it well-suited for deployment at high-power, multi-charger sites. 1. Main Power Circuit (Energy Path): Three-phase 380V AC power passes sequentially through an input circuit breaker, lightning protection and filtering circuitry, a Power Factor Correction (PFC) stage, an AC/DC rectification module, a DC-DC voltage regulation unit, a DC output fuse, and a high-voltage DC contactor, before finally reaching the positive and negative DC terminals of the charging connector. The charging module serves as the core power unit; the industry standard employs an N+1 modular redundancy design. Individual modules—available in 30kW, 40kW, or 60kW capacities—can be connected in parallel to form high-power commercial ev charging stations with outputs ranging from 60kW, 120kW, 180kW, and 240kW up to 480kW. Next-generation products increasingly utilize Silicon Carbide (SiC) MOSFETs in place of traditional IGBTs, which enhances conversion efficiency, reduces heat generation, and allows for a more compact footprint—with module conversion efficiencies reaching as high as 97% or more. 2. Control and Communication Circuit (The "Brain"): This includes the charging station’s main control MCU, a CAN communication unit, an OCPP-based cloud communication module, a human-machine interface (HMI) screen, and card reader/QR code scanning modules. The main controller is responsible for receiving commands from the vehicle’s Battery Management System (BMS), managing the output of the power modules, and reporting data to the backend operations platform. Under the Chinese national standard (GB/T) for DC charging, a CAN 2.0B bus is used for two-way communication with the vehicle’s BMS at a data rate of 250 kbit/s; meanwhile, the international CCS protocol also supports Power Line Communication (PLC). 3. Auxiliary Low-Voltage Circuit: This circuit provides a 12V low-voltage auxiliary power supply. During the initial "handshake" phase, it powers the vehicle’s BMS and high-voltage relays; the high-voltage DC circuit will not engage unless this low-voltage auxiliary power is active. 4. Cooling System: Small-to-medium power chargers typically utilize air cooling, whereas high-power chargers (above 180kW) and ultra-fast charging stations generally employ liquid cooling. This active cooling approach—applied to power modules, charging cables, and connector terminals—enables the system to continuously handle high currents while preventing excessive temperature rises that would otherwise necessitate a reduction in power output (derating). 5. Safety and Metering Unit: Includes insulation monitoring, residual current protection, emergency stop circuits, DC energy meters, temperature sensing, and high-voltage discharge circuits. It continuously monitors insulation resistance, leakage current, module temperature, and charging connector temperature.
In short: AC charging stations merely "deliver power," whereas DC charging stations incorporate a high-power power conversion system—effectively functioning as an external, high-power, programmable high-voltage power supply. II. Electrical Energy Conversion Chain: From AC Power Grid to DC Battery Power The system draws three-phase AC power from the grid, with the conversion process structured into two core stages. The first stage consists of Power Factor Correction (PFC) and AC-DC rectification: the three-phase AC input passes through an EMI filter and enters a PFC circuit, which shapes the input current to follow the voltage waveform—thereby reducing harmonic distortion and improving grid compatibility—before rectifying it into a stable DC bus voltage (the intermediate DC bus). The second stage involves an isolated DC-DC conversion: based on the target voltage specified by the Battery Management System (BMS), the bus voltage is precisely adjusted to fall within the allowable charging voltage range for the traction battery pack (approximately 250–450V for 400V-architecture vehicles, and a wider 200–800V range for 800V high-voltage architecture vehicles). This stage also dynamically limits the output current, enabling closed-loop power regulation. The entire energy conversion process is managed in real-time via a closed-loop control system; rather than providing a fixed voltage output, the unit functions as a variable DC power source that dynamically adjusts its output based on the state of the battery. III.Complete Standard Charging Process The entire charging process is divided into six standardized stages. The vehicle’s Battery Management System (BMS) holds full authority over high-voltage output, while the dc ev charger acts solely as an execution unit. This is the most critical safety design for DC fast charging, ensuring that the charging station cannot independently initiate high-voltage output. 1. Physical Connection Stage: The charging connector is inserted into the vehicle’s DC charging port and locked in place. The CC (Connection Confirmation) and CP (Control Pilot) signals verify a secure connection, ensuring the connector is properly docked with no risk of detachment. 2. Low-Voltage Auxiliary Power-Up: The dc ev charger provides a 12V low-voltage supply to wake up the vehicle’s BMS. The BMS then performs a self-check and activates the high-voltage system. 3. Charging Handshake Stage: A communication link is established via the CAN bus. The charging station transmits its capabilities—including maximum voltage, maximum current, and rated power—to the vehicle. The BMS responds with a handshake message containing basic battery information, the maximum allowable charging voltage, and the battery temperature range. If any communication error or handshake failure occurs, the process is immediately terminated, and high-voltage output is strictly prohibited. 4. Charging Parameter Configuration and Insulation Detection: The BMS sends a charging request message, specifying the maximum allowable current and target voltage for the session. Both the charging station and the vehicle perform an insulation test on the high-voltage circuit, measuring the insulation resistance of the positive and negative terminals relative to the ground; if the insulation fails the check, the high-voltage system is locked out. Once the check is complete, the vehicle closes its internal high-voltage contactors, followed by the charging station closing its own DC contactors. This facilitates a "high-voltage pre-charge" phase, which prevents inrush currents from damaging the battery or other components. Pre-charging is a vital protective measure: a small current is used to charge the capacitors on the vehicle’s high-voltage bus, and only after the voltage differential is balanced is the full circuit engaged, thereby suppressing surge currents. 5. Charging Stages (Two-stage curve: Constant Current → Constant Voltage) 5.Constant Current Stage (typically from 0% to 80% SOC): When the battery voltage is below the cutoff threshold, the BMS permits a high-current input. The charging station maintains a constant current output, while the voltage rises gradually in line with the battery voltage; this is the phase with the fastest charging speed. Constant Voltage/Decreasing Current Stage (SOC > 80%): Once the battery voltage reaches its rated upper limit, the BMS instructs the charging station to lock the voltage and progressively reduce the charging current. The current continues to taper off until the SOC approaches 100%. This is why charging slows down significantly after reaching 80% SOC—it is an electrochemical protection mechanism inherent to lithium-ion batteries, not a malfunction of the charging station. Throughout the entire charging process, data is reported bidirectionally multiple times per second, including individual cell voltages, total battery pack voltage, cell temperatures, SOC, and the maximum current limit set by the BMS. If issues such as cell overheating, excessive voltage differential, or a drop in insulation resistance occur, the BMS immediately issues a command to halt charging. 6. Termination of Charging (Normal or Abnormal): Whether due to the BMS determining the battery is fully charged, the user stopping the process, an emergency stop being triggered, a communication failure, or an event like overheating or electrical leakage, a shutdown sequence is initiated. The charging station first reduces the current to zero, opens the DC contactors, and activates a high-voltage discharge circuit to dissipate any residual charge from the bus capacitors. Only after this process is complete is the charging connector unlocked, ensuring it is safe to unplug. IV. Core Security Protection Mechanisms
DC charging stations operate under conditions involving high voltages (hundreds of volts) and high currents (hundreds of amperes). They incorporate multiple layers of hardware and software protection, including: insulation monitoring, leakage protection, overvoltage and undervoltage protection, overcurrent protection, module over-temperature protection, charging connector temperature monitoring, emergency stop buttons, high-voltage discharge mechanisms, and protection against CAN communication heartbeat timeouts. If any of these safety thresholds are triggered, the system cuts off the high-voltage output within milliseconds and logs the fault for transmission to the backend management system. V. Common Misconceptions Misconception 1: Higher power output always guarantees faster charging.
Incorrect. The actual charging limit is determined by the maximum charging power permitted by the Battery Management System (BMS). If a vehicle’s battery pack only supports 100kW, a 240kW charging station will still only deliver 100kW.
Misconception 2: DC charging stations feed power directly into the battery without requiring any control.
Incorrect. The BMS dictates the charging strategy, while the charging station functions merely as a power-delivery device.
Misconception 3: The slowdown in charging speed after reaching 80% capacity is caused by the charging station limiting the current.
Incorrect. This is actually a fundamental characteristic of constant-voltage charging for lithium-ion batteries, designed to prevent lithium plating and avoid damaging the battery cells. Conclusion
The DC charging pile is essentially a grid-connected high-power AC-DC programmable power supply system that relies on the standardized CAN handshake protocol and BMS collaboration to dynamically output high-voltage DC power according to the lithium battery safe charging curve. Understanding the working principle of DC charging piles will not only help station operation and maintenance personnel troubleshoot faults, but also help car companies, equipment purchasers, and new energy practitioners understand the differences in fast charging solutions. With the popularization of 800V high-voltage platforms and the large-scale implementation of silicon carbide devices and liquid-cooled supercharging, the power density, conversion efficiency, and charging speed of DC fast charging will continue to improve, supporting the continued improvement of long-distance travel networks for electric vehicles.


.jpg)
.jpg)